Portrait of Hasan Bakir Hey, I’m Hasan Open to work

An AI Engineer building reliable, production-ready systems at scale.

I focus on computer vision and applied AI — designing, training, and deploying deep-learning systems that hold up in real-world conditions.

I most recently spent over a year as an AI engineer at AYGAZ (Koç Group), shipping production vision systems — from real-time monitoring and inspection to AI-assisted data pipelines.

Before that, I built autonomous UAV systems as a two-time TEKNOFEST finalist, published IEEE research, shipped a TÜBİTAK-funded IoT product, and joined a NASA Space Apps global-nominee team.

I care about clean architecture, measurable performance, and systems that survive contact with production — on the edge as well as in the cloud.

Contact me

IEEE 2024 published  ·  NASA Space Apps — Global Nominee  ·  Open to full-time CV / AI roles

/work.

Selected work I’ve taken on — sports analytics, IoT hydration, and two autonomous UAV inspection projects. All run in real time, on real hardware.

01 — Detection · Tracking · Pose · BEV — 2026

Basketball Game Tracker Pipeline

Multi-modal sports analytics: player detection, persistent tracking, jersey-number OCR, pose estimation, instance segmentation, and bird’s-eye-view homography — accelerated with ONNX / TensorRT for real-time inference.

RF-DETR · ByteTrack · PARSeq · YOLO-Pose · SAM + Cutie · TensorRT

View on GitHub live inference
BEV · tactical

02 — Aerial inspection · TEKNOFEST Finalist — 2023–2024

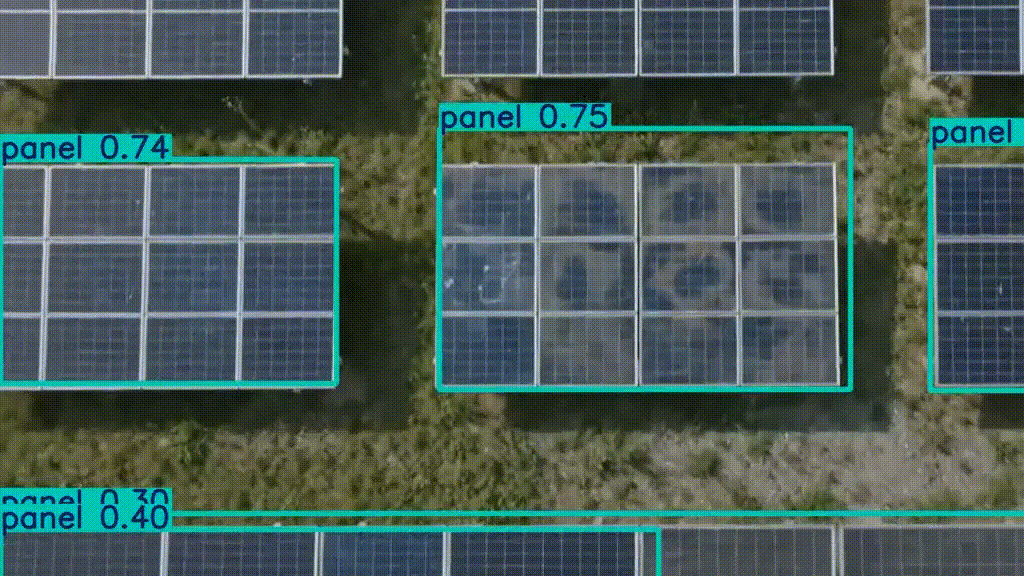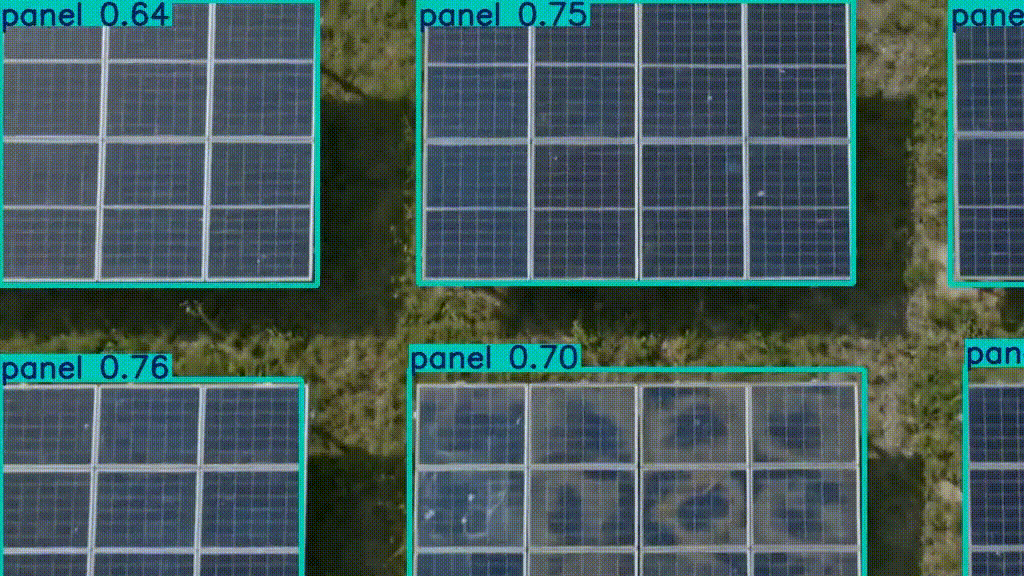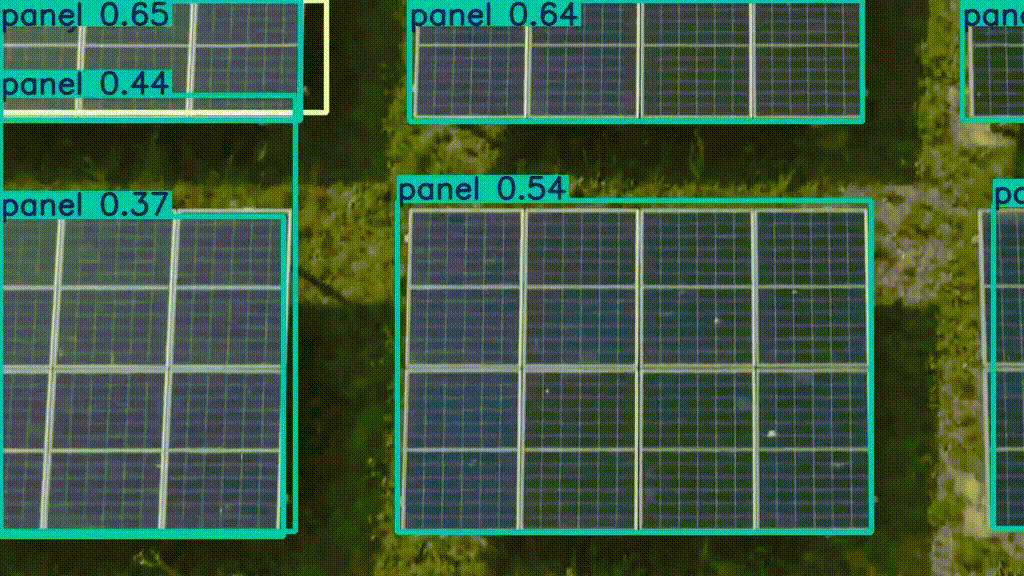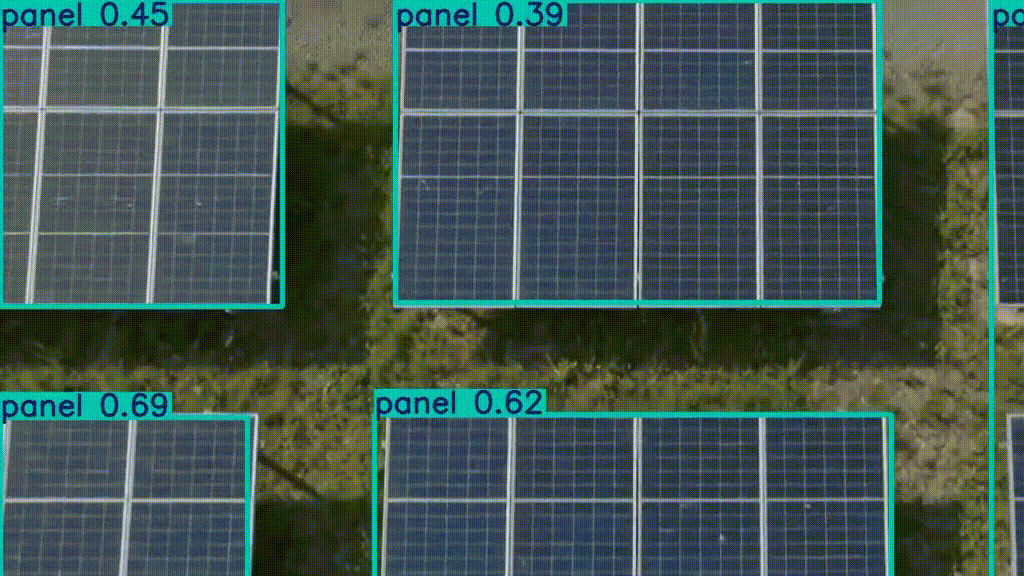
Aerial Solar-Panel Defect Inspection

Top-down drone imagery through a YOLO detector that localizes panels and flags dust, soiling, cracks and bird droppings — for real-time panel-health analytics on embedded hardware.

YOLOv8/v5 · Defect Detection · UAV · Raspberry Pi

View on GitHub TEKNOFEST · finalist
Drone solar-panel defect detection

03 — Air-to-air detection · Embedded — 2023–2024

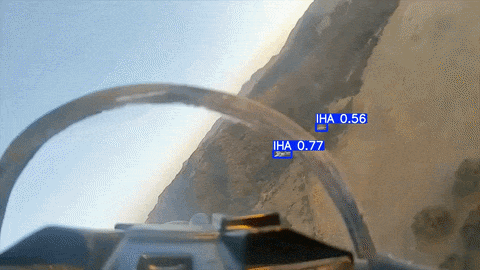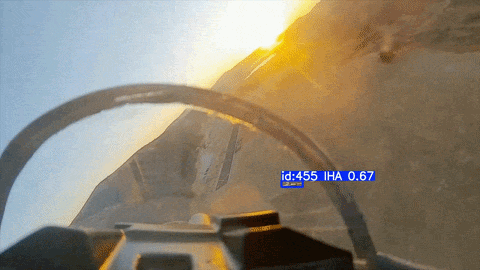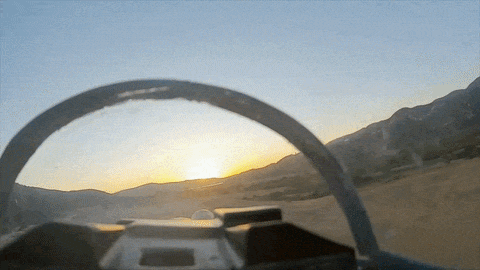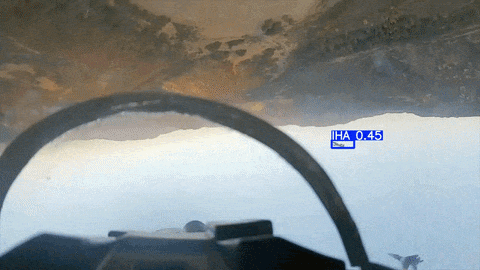
Autonomous Combat-UAV Target Detection

Onboard air-to-air detection: a real-time YOLO model locks onto rival aircraft from the drone’s own camera under fast motion and cluttered terrain — trained on Roboflow data, deployed on Raspberry Pi.

YOLO · Roboflow · Raspberry Pi · Real-time

onboard inference · code available on request
Combat UAV target detection

04 — IoT · Embedded · Mobile · LLM — 2024–2026 · No video, hardware product

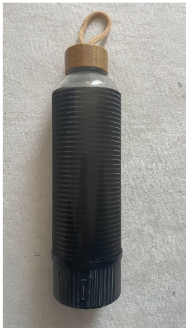
WaterMate — Smart Hydration System

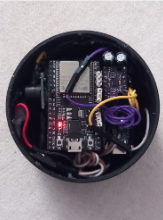
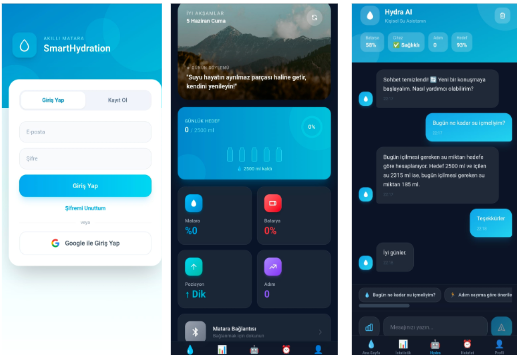
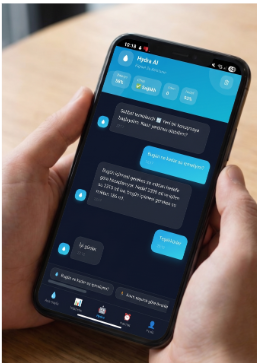
TÜBİTAK 2209-A funded IoT smart bottle: custom capacitive level sensor, IMU-based drinking-gesture recognition, offline SD logging, BLE-to-Firebase sync via a Flutter app, and a GPT-4o-mini coach for personalized hydration.

ESP32 · BLE · C++ · Flutter · Firebase · GPT-4o-mini

Request demo Private repo · prototype & app
WaterMate smart bottleBottle
ESP32 electronicsESP32 base
Flutter app screensFlutter app
Hydra AI chatHydra AI

/experience.

Industry, competition, and education — the short version. Full details are in my resume.

Dec 2024 – Feb 2026

AYGAZ

AI Software Developer 1+ year · production

AYGAZ (Koç Group) — Istanbul · Long Term Intern

  • Dual-vision truck monitoring — YOLOv11 + ByteTrack at 30–45 FPS, ONNX/TensorRT optimized.
  • License-plate OCR pipeline at ~100% accuracy on factory vehicles.
  • Packaging inspection with OpenCV + YOLO + relay-halt hardware integration.
  • Agentic RAG (LLaMA / Mistral + NL→SQL) and Isolation Forest anomaly detection.
  • FastAPI “Digital Factory” platform with SeqLog centralized logging.

2025

NASA Space Apps

Competition

NASA Space Apps Challenge Global Nominee · Top 10%

SHIFT Team — seismic dashboard · Local 2nd place

  • Built SHIFT: seismic data analysis and early-warning platform on NASA datasets.
  • Interactive real-time earthquake monitoring dashboard + public risk visualization.

Oct – Nov 2024

AISOFT

Computer Vision Engineering Intern

AISOFT — Sakarya · TÜBİTAK-supported stitching project

  • Image stitching (ORB/SIFT, homography) and Pandas/Matplotlib data pipelines.

2023 – 2024

TEKNOFEST

Competition

Poyraz Havacılık — International UAV Finalist

Dual-UAV autonomous solar-farm inspection

  • YOLOv8/v5 defect detection (cracks, soiling) with real-time processing on Raspberry Pi, plus panel-health analytics reporting.

2023 – 2024

TEKNOFEST

Competition

İLGERU — Combat UAV Software Team

Autonomous air-to-air target detection

  • Computer vision for autonomous target detection; managed dataset annotation in Roboflow.
  • Deployed real-time YOLO inference on embedded Raspberry Pi hardware.

2022 – 2026

Sakarya University

Education

B.Sc. Computer Engineering

Sakarya University — GPA 3.02 / 4.00

/shelf.

Papers and writing — things worth keeping.

/stack.

The toolbox I reach for.

Languages

Python, C++, C, SQL, Java

CV & Deep Learning

YOLOv8/v11, RF-DETR, ByteTrack, U-Net, SAM, YOLO-Pose, OCR

ML & AI

PyTorch, TensorFlow, Scikit-learn, LightGBM, LLaMA, Mistral, RAG, LangChain

MLOps & Deployment

FastAPI, Docker, ONNX, TensorRT, Git, Azure DevOps, Firebase

Libraries & Tools

OpenCV, NumPy, Pandas, Ultralytics, Roboflow, Linux

Embedded & Spoken

ESP32, BLE, IMU, Flutter · Turkish (Native), English (B2)

/contact.

Let’s build something that runs in real time.

I’m open to full-time Computer Vision / AI and MLOps roles in Turkey and internationally. Fastest way to reach me is email — I usually reply within a day.
524hasanbakr@gmail.com

You just navigated to: /